2025–present · UMass Robotics · Electrical co‑lead
UMass Robotics
Three legged robots, one electrical team. I co‑lead it: reviewing the boards the subteams make, finishing the gateway that ties the quadruped together, and guiding the people building the next version of it.
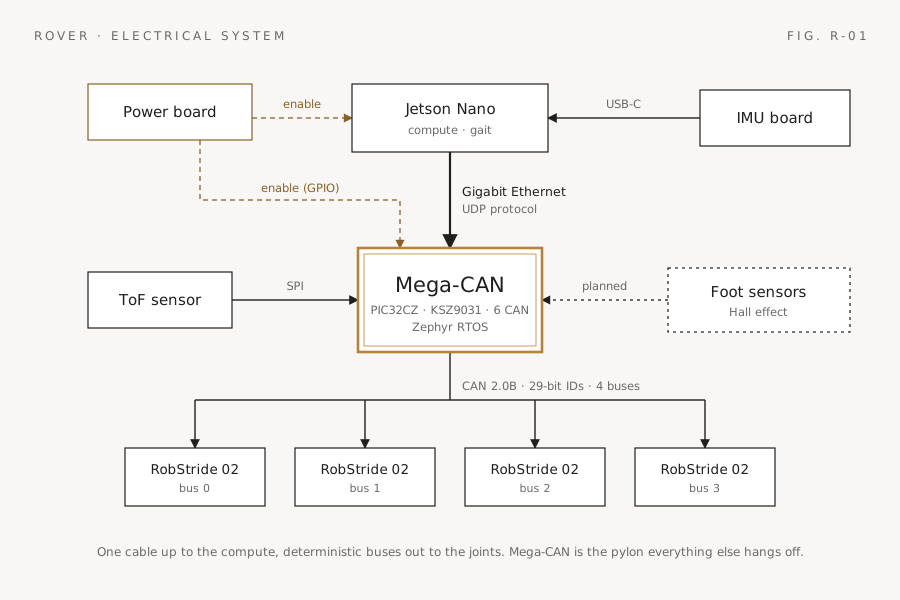
Where Mega‑CAN sits
Rover’s Jetson Nano does the thinking; Mega‑CAN does the talking. One gigabit Ethernet cable carries a UDP protocol down from the Jetson, and Mega‑CAN fans it out over four CAN 2.0B buses to the RobStride 02 actuators at the joints. Sensors hang off it too: a time‑of‑flight sensor over SPI now, Hall‑effect foot sensors next. The power board enables both the Jetson and Mega‑CAN, and the IMU board reaches the Jetson over USB‑C.
The three robots · and what I do on each
I · Quadruped
Rover
The dog. I review every PCB the team develops, finalize Mega‑CAN and its migration to CAN 2.0B for the RobStride 02 actuators, and lead final integration testing before it walks.
II · Biped · feet or wheels
Wobble
A biped whose feet swap out for wheels. The team owns its board; I review the design and stay hands‑off otherwise.
III · Biped · shoe‑testing platform
ShoeMass
A biped built to test shoes, developed with a UMass faculty lab and industry footwear partners. I guide five people: two on foot‑sensor force mapping, three redesigning Mega‑CAN as V2, which we will program together.
What co‑lead means here
Mostly reviews and decisions. I check boards before they go to fabrication and again when they come back, settle the interfaces between subteams, and keep one picture of how the whole robot is wired so nobody has to guess.
Where it stands, honestly
Rover is closest: its boards are fabricated, and Mega‑CAN’s firmware builds and is waiting on bench bring‑up. Wobble and ShoeMass are earlier. ShoeMass will take the longest, and it is the one I am most excited about.